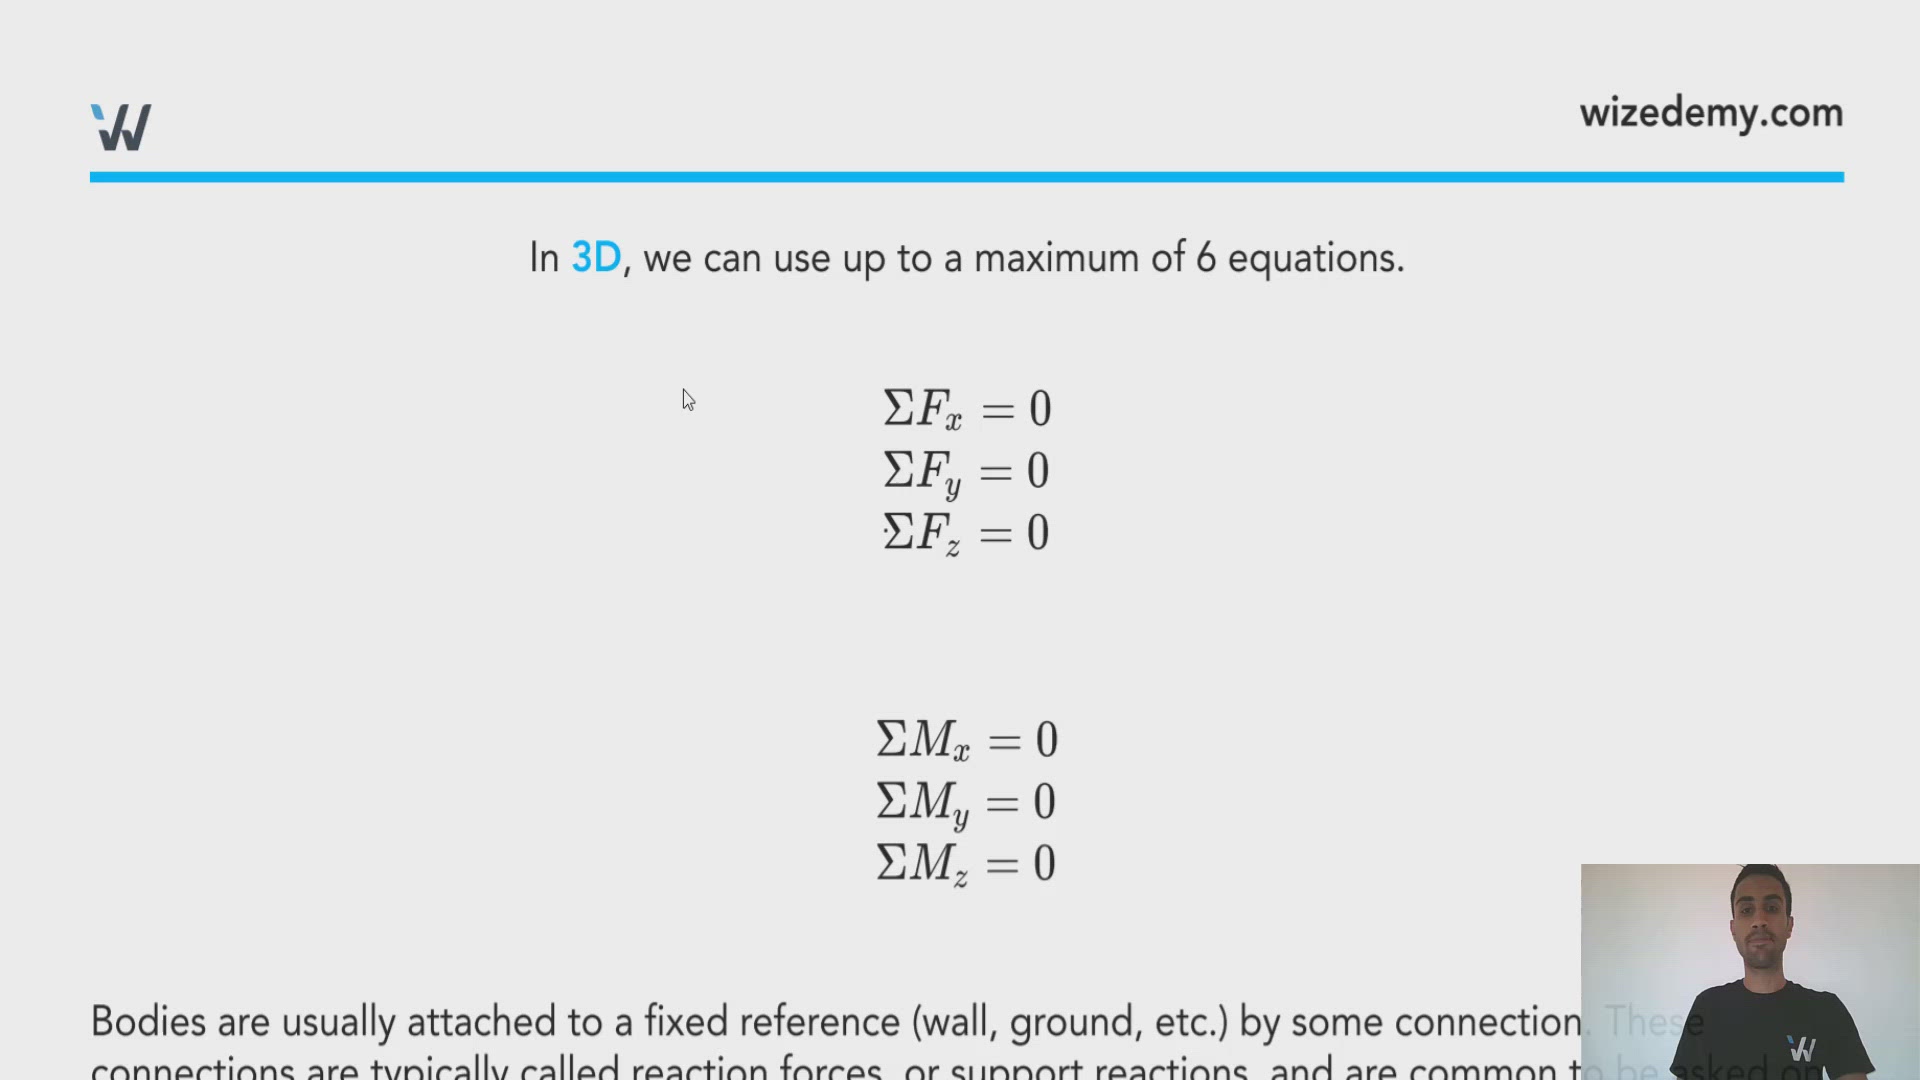
In 3D, we can use up to a maximum of 6 equations.
Bodies are usually attached to a fixed reference (wall, ground, etc.) by some connection. These connections are typically called reaction forces, or support reactions, and are common to be asked on a question. As you may notice, there are many types of support reactions.
A brief review of these reactions follows:


As always, to solve a system of equations, you can have a maximum number of unknowns equal to the number of equations – up to 6 unknowns in 3D. Therefore, we sometimes simplify the unknown reaction forces to reduce the number of unknowns by:
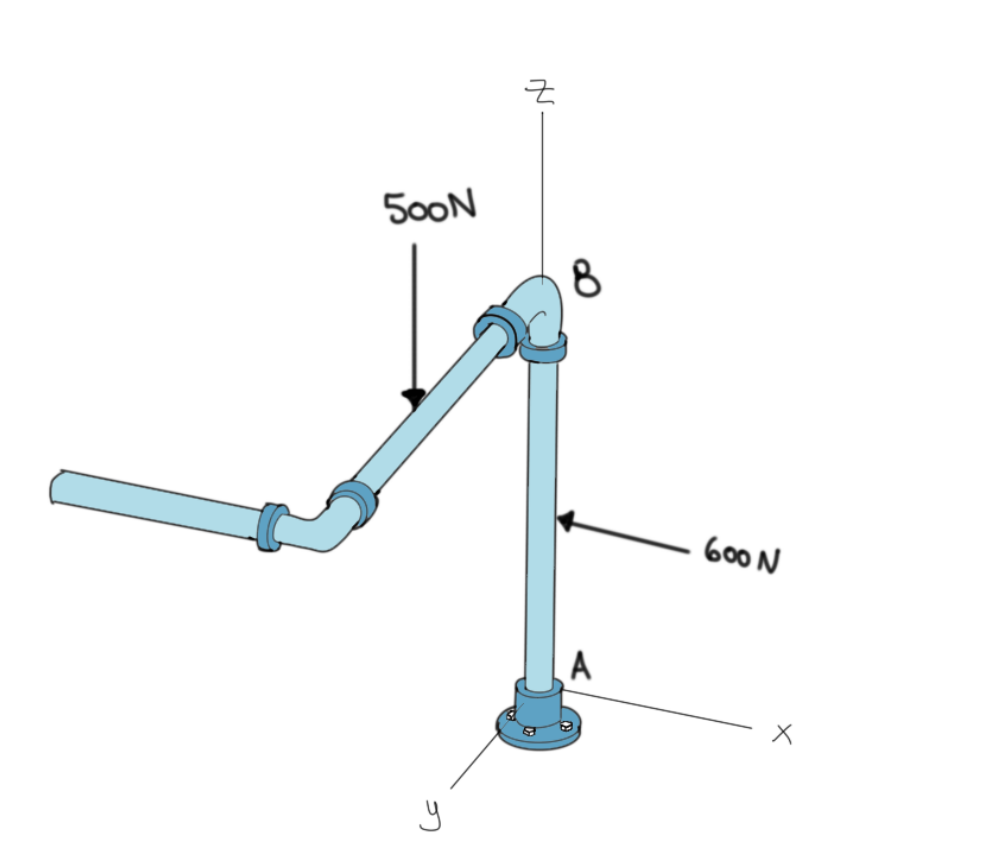
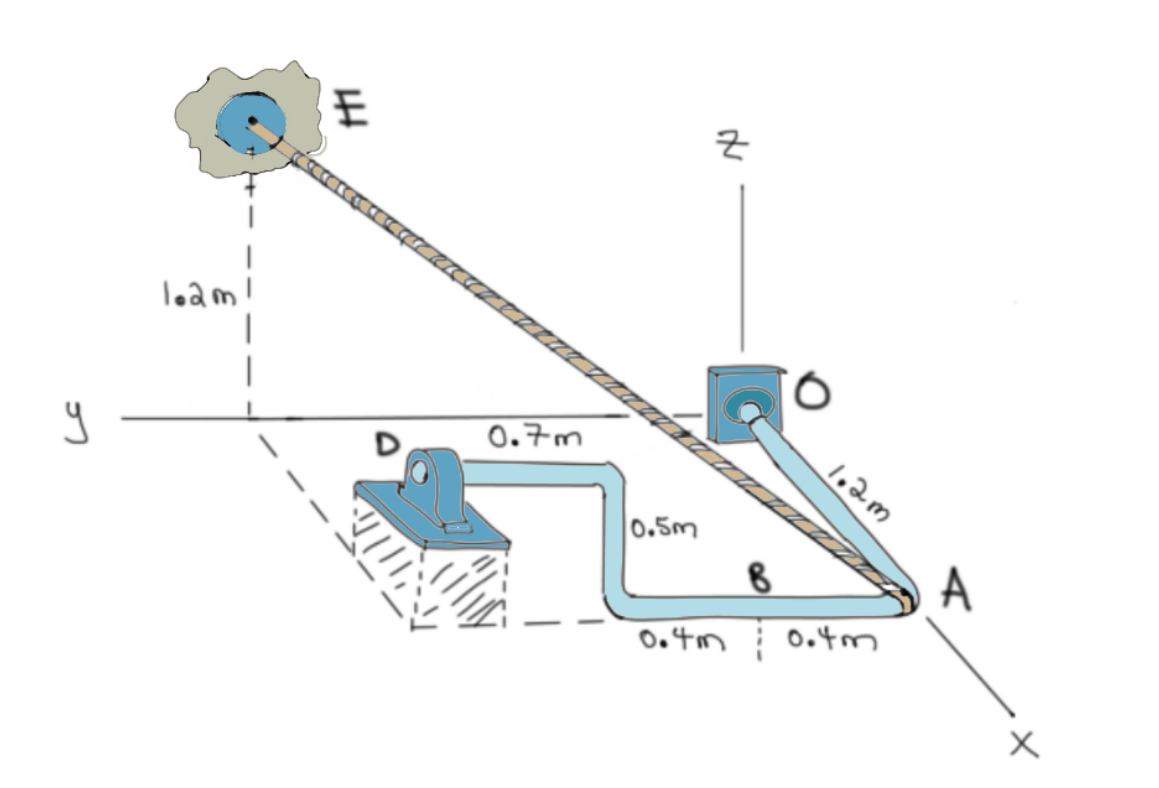
Lets Draw The FREE BODY DIAGRAMS for the following cases:

Example
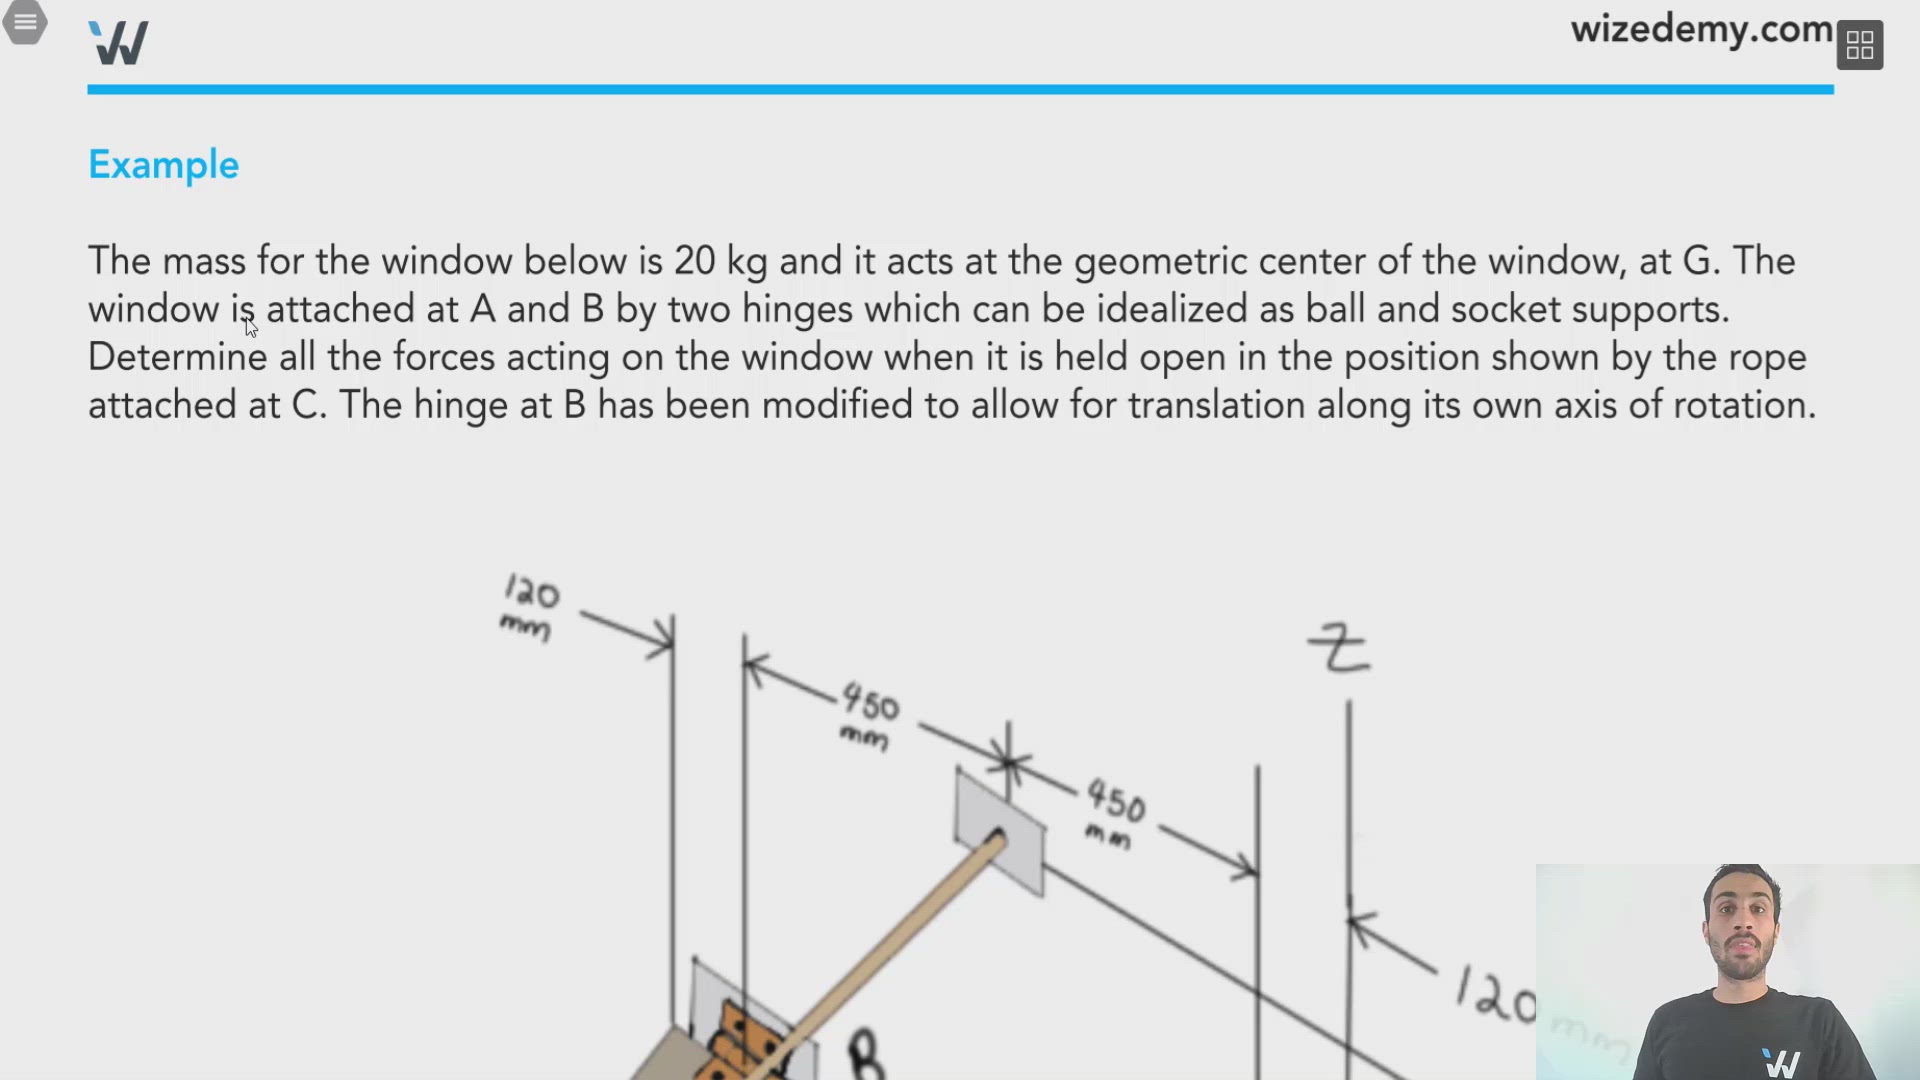
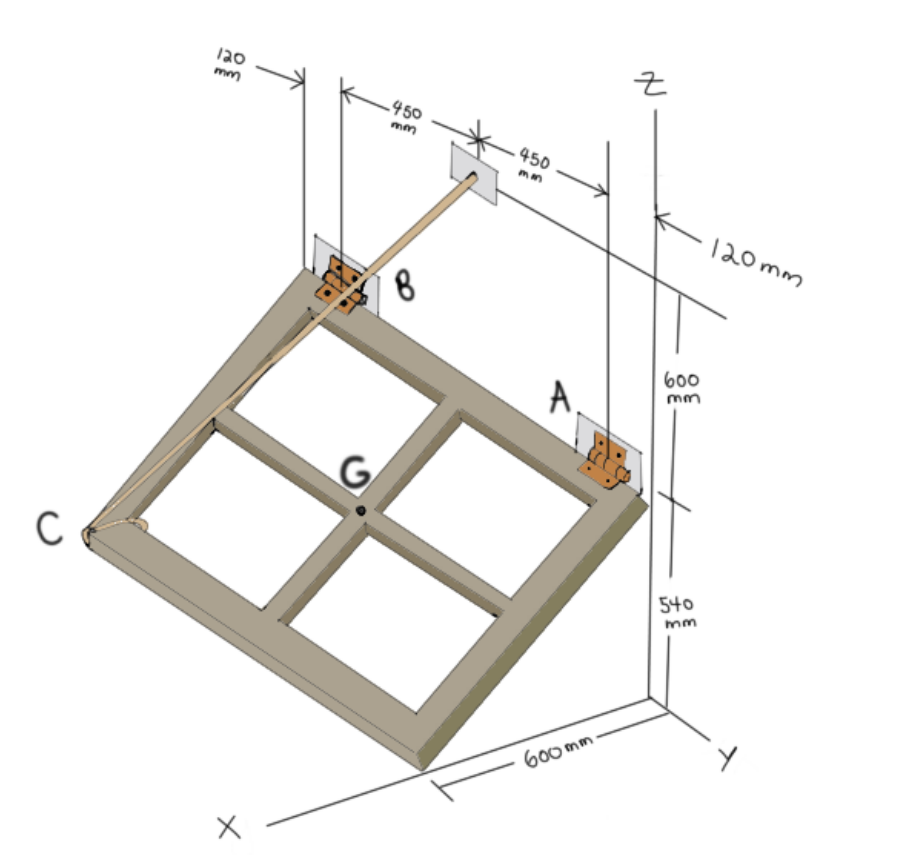
The mass for the window below is 20 kg and it acts at the geometric center of the window, at G. The window is attached at A and B by two hinges which can be idealized as ball and socket supports. Determine all the forces acting on the window when it is held open in the position shown by the rope attached at C. The hinge at B has been modified to allow for translation along its own axis of rotation.
Solution:
1) Draw Free Body Diagram, notice the hinge (ball and socket support) at B has been modified to allow for axial translation along the y-axis (axis of rotation for the hinge) so there is NO By reaction.

2) Determine all forces and moments in cartesian vector form
Cable force CD,
Weight,
Reaction forces,
3) Apply 3D Force Equations of Equilibrium and Equate i, j, and k components from the Forces above,
Notice we couldn’t solve for anything using the equations of equilibrium from above. We need to take the moment about a point where we can eliminate the most unknowns. This is point A!
4) Moment equation of equilibrium about point A,
We need the position vectors
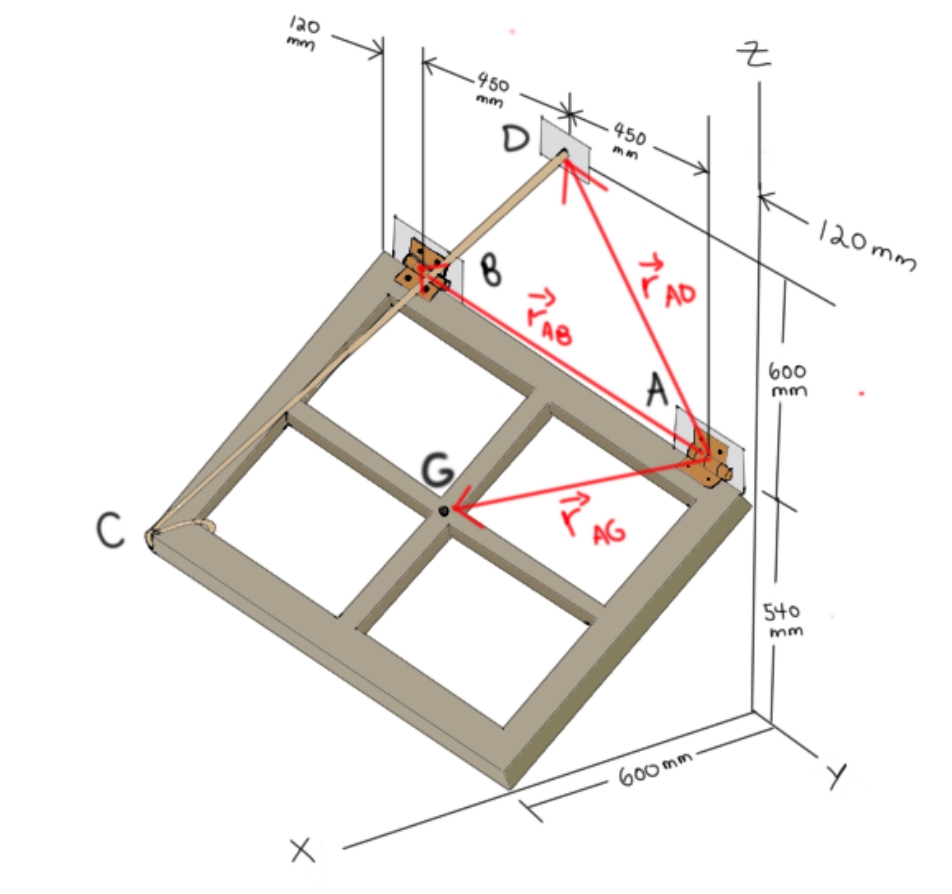
Therefore,
5) Equate i j and k Components,
6) We can find TCD using the equation (5),
Plug TCD into equation (6) and solve for Bx,
Plug TCD into equation (4) and solve for Bz,
7) Solve for the reactions at A, using our initial equilibrium equations (1), (2), (3)
Example
The mass for the window below is 20 kg and it acts at the geometric center of the window, at G. The window is attached at A and B by two hinges which can be idealized as ball and socket supports. Determine all the forces acting on the window when it is held open in the position shown by the rope attached at C. The hinge at B has been modified to allow for translation along its own axis of rotation.
Solution:
1) Draw Free Body Diagram
2) Determine all forces and moments in cartesian vector form
Cable force CD,
Weight,
Reaction forces,
3) Apply 3D Force Equations of Equilibrium and Equate i, j, and k components from the Forces above,
Notice we couldn’t solve for anything using the equations of equilibrium from above. We need to take the moment about a point where we can eliminate the most unknowns. This is point A!
4) Moment equation of equilibrium about point A,
We need the position vectors
Therefore,
5) Equate i j and k Components,
6) We can find TCD using the equation (5),
Plug TCD into equation (6) and solve for Bx,
Plug TCD into equation (4) and solve for Bz,
7) Solve for the reactions at A, using our initial equilibrium equations (1), (2), (3)
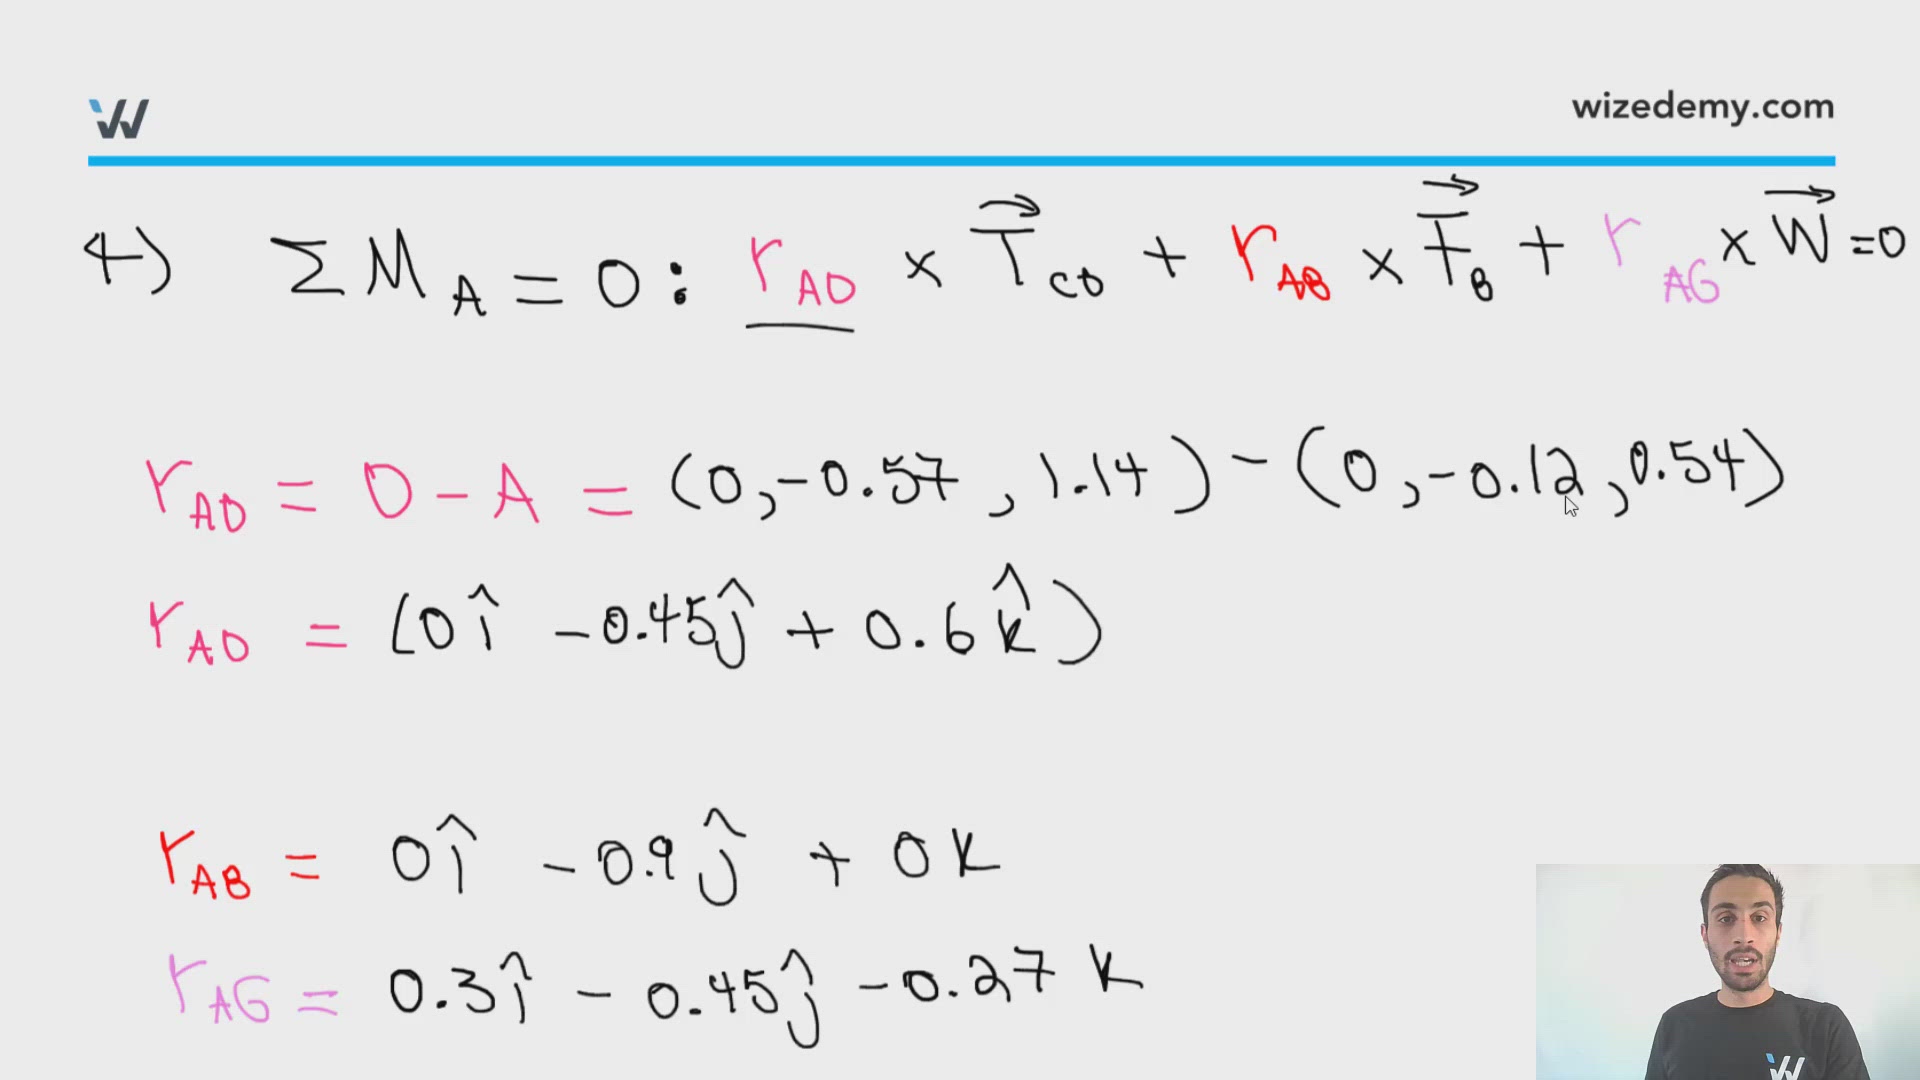
Example
The mass for the window below is 20 kg and it acts at the geometric center of the window, at G. The window is attached at A and B by two hinges which can be idealized as ball and socket supports. Determine all the forces acting on the window when it is held open in the position shown by the rope attached at C. The hinge at B has been modified to allow for translation along its own axis of rotation.
Solution:
1) Draw Free Body Diagram
2) Determine all forces and moments in cartesian vector form
Cable force CD,
Weight,
Reaction forces,
3) Apply 3D Force Equations of Equilibrium and Equate i, j, and k components from the Forces above,
Notice we couldn’t solve for anything using the equations of equilibrium from above. We need to take the moment about a point where we can eliminate the most unknowns. This is point A!
4) Moment equation of equilibrium about point A,
We need the position vectors
Therefore,
5) Equate i j and k Components,
6) We can find TCD using the equation (5),
Plug TCD into equation (6) and solve for Bx,
Plug TCD into equation (4) and solve for Bz,
7) Solve for the reactions at A, using our initial equilibrium equations (1), (2), (3)
Disclaimer: At 16:15 of video it should read "Ay=-800N".
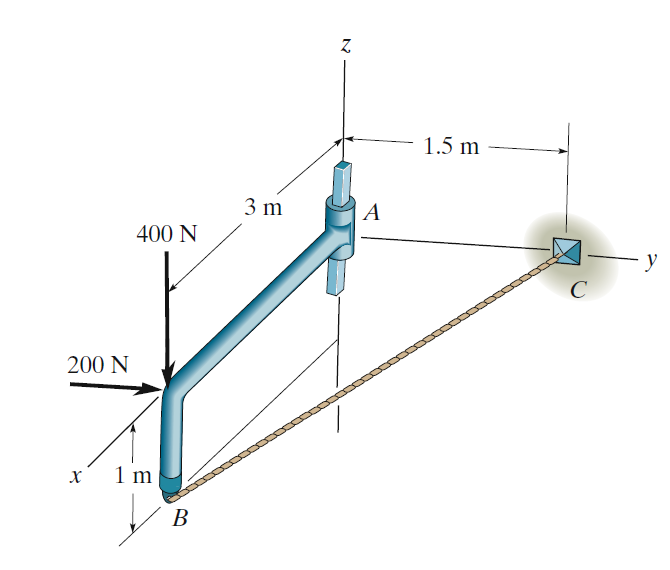
Member AB is supported by a cable BC and at A by a square rod which fits loosely through the square hole in the
collar fixed to the member as shown.
(a) (3 marks) Write the cable force T as a vector component.
(b) (8 marks) Determine the reactions at A.
Solution:
1) Draw Free Body Diagram.
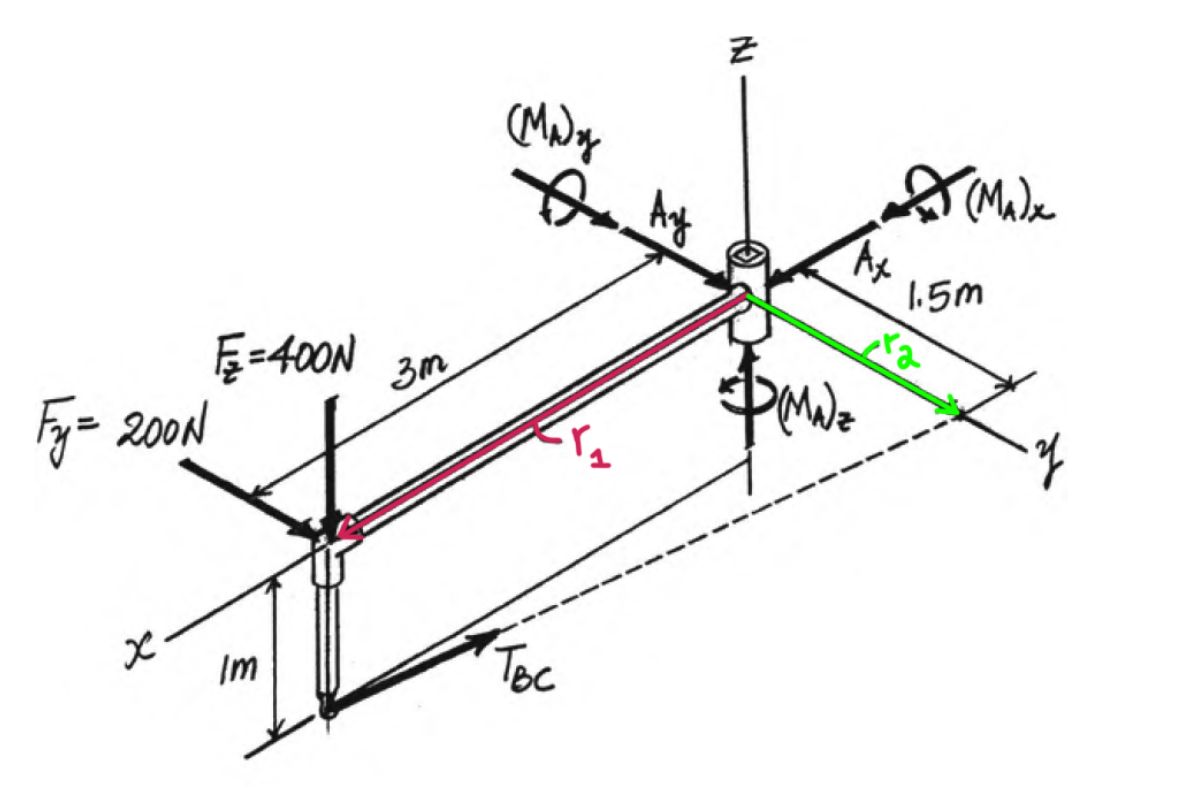
2) Determine all forces and moments in cartesian vector form
Cable force CD,
Applied forces,
Reaction forces,
Reaction moment,
3) Apply 3D Force Equations of Equilibrium and Equate i, j, and k components from the Forces above,
From Eqs (1) to (3), we get,
4) Moment equation of equilibrium about point A,
We need the position vectors
Therefore,
5) Equate i j and k Components,
Plug TBC=1400 N into equations (4), (5), and (6) and solve for the moment reactions,